Publications

Publications and manuscripts in reverse chronological order.

2027

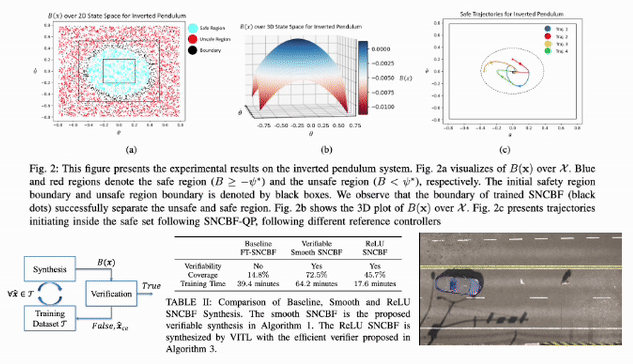
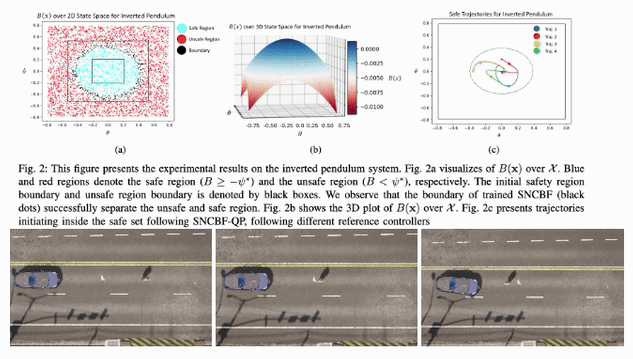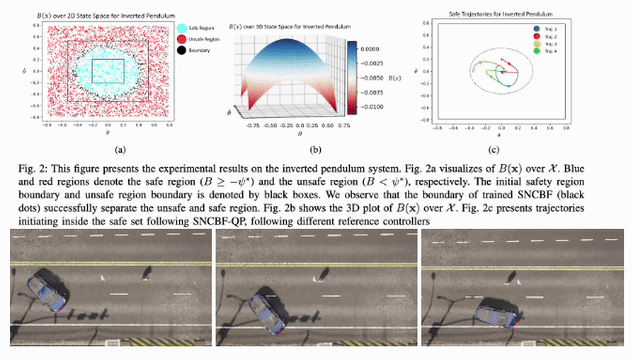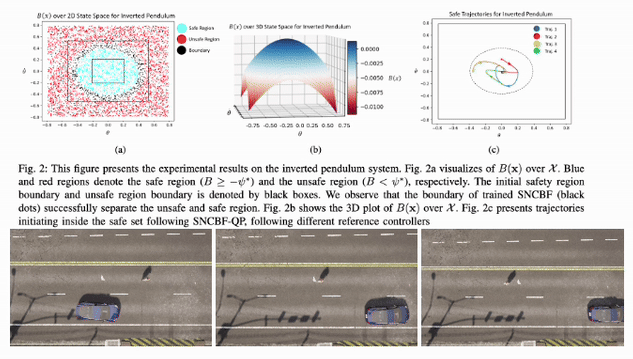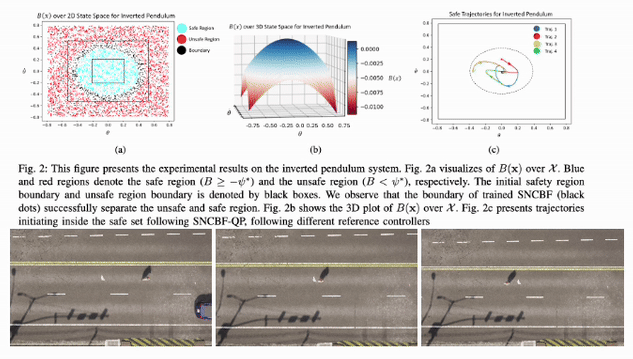
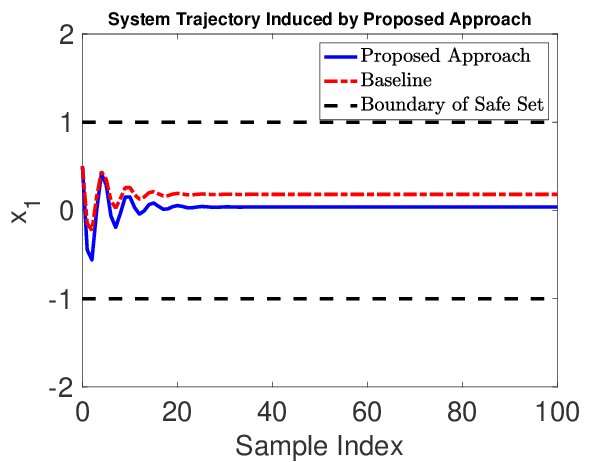
  1. Stochastic Neural Control Barrier Functions Stochastic Neural Control Barrier Functions
    Stochastic Neural Control Barrier Functions
    Hongchao Zhang, Manan Tayal, Jackson Cox, and
    IEEE Transactions on Automatic Control, Mar 2027
    To appear March 2027
  2. A Self-correcting Neuro-symbolic AI Reasoning Framework
    Ben Wooding, Kiersten Brennan, Anne M. Tumlin, and
    In AI Verification (SAIV 2026), 2027
    Springer LNCS 16831; citation year: 2027; first online: 18 July 2026
  3. Semi-Implicit Belief Approximation with Learned Transport and Reweighting for POMDPs (Under review)
    Yunuo Zhang, Nathaniel S. Keplinger, Hongchao Zhang, and
    2027
    Under review at ICLR 2027
  4. Error Localization and Steering of Language Model Quantitative Reasoning (Under review)
    Hongchao Zhang, Guocheng He, Ben Wooding, and
    2027
    Under review at ICLR 2027
  5. Generalist Graph Anomaly Detection via a Spectral Vocabulary (Under review)
    Yilin Liu, Hongchao Zhang, Ahmad Taha, and
    2027
    Under review at ICLR 2027
  6. Input-Agnostic Probabilistic Neural Network Verification for Vision, Speech and Depth (Under review)
    Ben Wooding, Anne Marie Tumlin, Samuel Sasaki, and
    2027
    Under review at AAAI 2027
  7. Formal Method Guided Multi-Agent Optimization Formulation (Under review)
    Guocheng He, Lingwen Deng, Ahmad Taha, and
    2027
    Under review at AAMAS 2027
  8. Robustness Verification of First-to-Fire Spiking Neural Networks (Under review)
    Aarij Atiq, Samuel Sasaki, Ben Wooding, and
    2027
    Under review at TACAS 2027

2026

  1. Modeling Spectral Energy Shifts in Spatio-Temporal Graph Anomaly Detection
    Yilin Liu, Hongchao Zhang, Ahmad Taha, and
    In Proceedings of the 43rd International Conference on Machine Learning, 2026
  2. Control Barrier Function Synthesis for Differential-Algebraic Systems
    Hongchao Zhang, Mohamad H. Kazma, Ben Wooding, and
    In IEEE Conference on Decision and Control, 2026
    To appear
  3. Safe Control of Semi-Explicit Differential-Algebraic Systems: Control Barrier Functions with SOS Verification
    Mohamad H. Kazma, Hongchao Zhang, Abdallah A. Albustami, and
    In IEEE Conference on Decision and Control, 2026
    To appear
  4. Safe Autonomous Takeover for Unknown Descriptor Systems
    Ben Wooding, Mohamad H. Kazma, Hongchao Zhang, and
    In IEEE Conference on Decision and Control, 2026
    To appear
  5. k-Inductive Neural Barrier Certificates for Unknown Nonlinear Dynamics
    Ben Wooding, Hongchao Zhang, Taylor T. Johnson, and
    In 3rd International Conference on Neuro-symbolic Systems (NeuS’26), 2026
  6. NNV3: Expanding Neural Network Verification to New Architectures and Domains
    Anne M. Tumlin, Samuel Sasaki, Ben Wooding, and
    In 24th International Symposium on Automated Technology for Verification and Analysis (ATVA), 2026
    To appear; A. M. Tumlin and S. Sasaki contributed equally
  7. PACE: A Personalized Adaptive Curriculum Engine for 9-1-1 Call-taker Training
    Zirong Chen, Hongchao Zhang, and Meiyi Ma
    In Proceedings of the Thirty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-26, Aug 2026
    AI and Social Good
  8. BehaVerify: A Formal Verification Tool for Behavior Trees
    Serena Serbinowska, Ben Wooding, Diego Manzanas Lopez, and
    In 8th International Workshop on Formal Methods for Autonomous Systems (FMAS), Nov 2026
    To appear
  9. Verification and Forward Invariance of Control Barrier Functions for Differential-Algebraic Systems (Under review)
    Hongchao Zhang, Mohamad H. Kazma, Meiyi Ma, and
    International Journal of Robust and Nonlinear Control, 2026
    Under review
  10. Safe Flight in Cluttered Indoor Environments: A Verified Union of Neural Control Barrier Functions (Under review)
    Ben Wooding, Hongchao Zhang, and Taylor T. Johnson
    2026
    Under review at the IEEE International Conference on Robotics and Automation; B. Wooding and H. Zhang contributed equally

2025

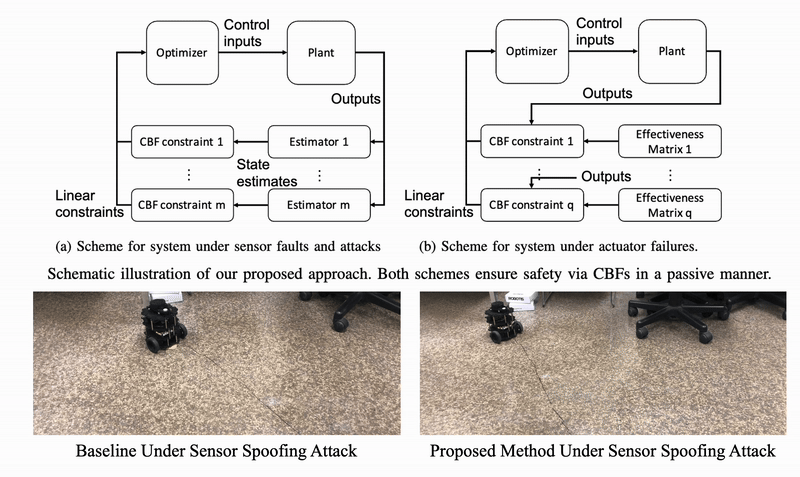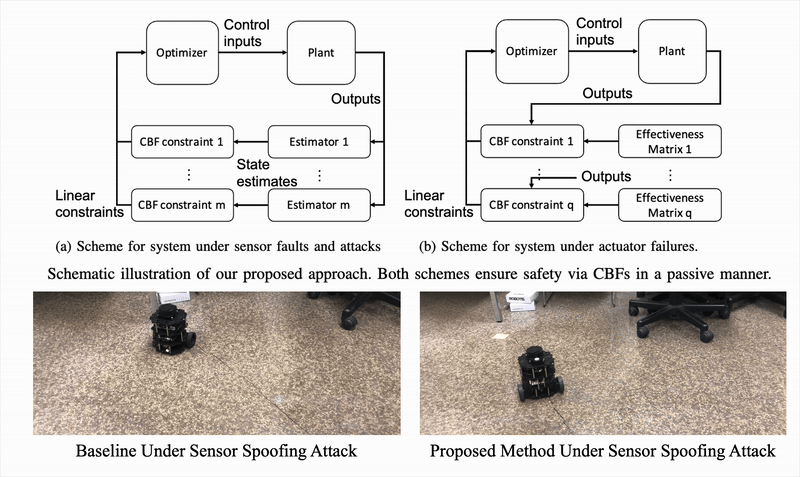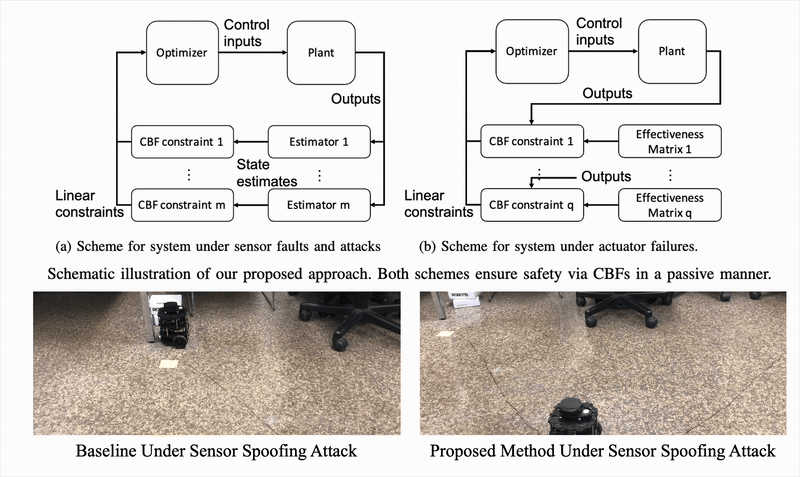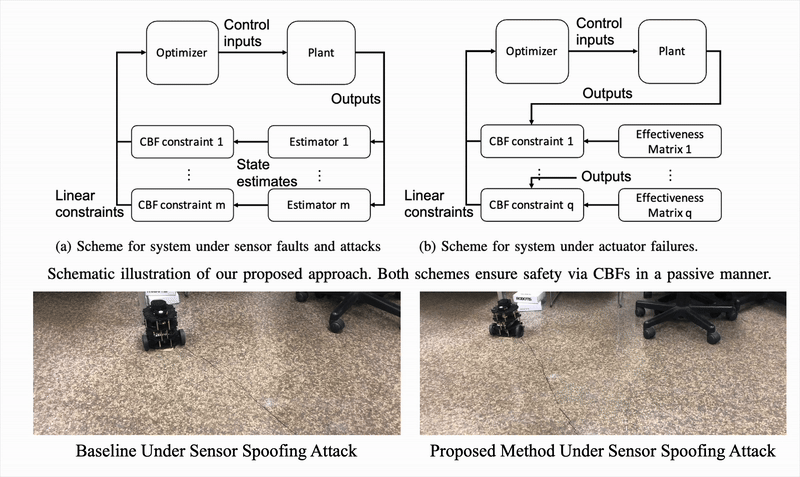
  1. Safe Control for Nonlinear Systems Under Faults and Attacks Via Control Barrier Functions Safe Control for Nonlinear Systems Under Faults and Attacks Via Control Barrier Functions
    Safe Control for Nonlinear Systems Under Faults and Attacks Via Control Barrier Functions
    Hongchao Zhang, Zhouchi Li, and Andrew Clark
    IEEE Transactions on Automatic Control, Nov 2025
  2. ConTest: Taming the Cyber-physical Input Space in Fuzz Testing with Control Theory
    Jinwen Wang, Hongchao Zhang, Chuanrui Jiang, and
    In Proceedings of the ACM SIGSAC Conference on Computer and Communications Security, 2025
    J. Wang and H. Zhang contributed equally

2024

  1. SEEV: Synthesis with Efficient Exact Verification for ReLU Neural Barrier Functions
    SEEV: Synthesis with Efficient Exact Verification for ReLU Neural Barrier Functions
    Hongchao Zhang, Zhizhen Qin, Sicun Gao, and
    In Advances in Neural Information Processing Systems, 2024
    H. Zhang and Z. Qin contributed equally
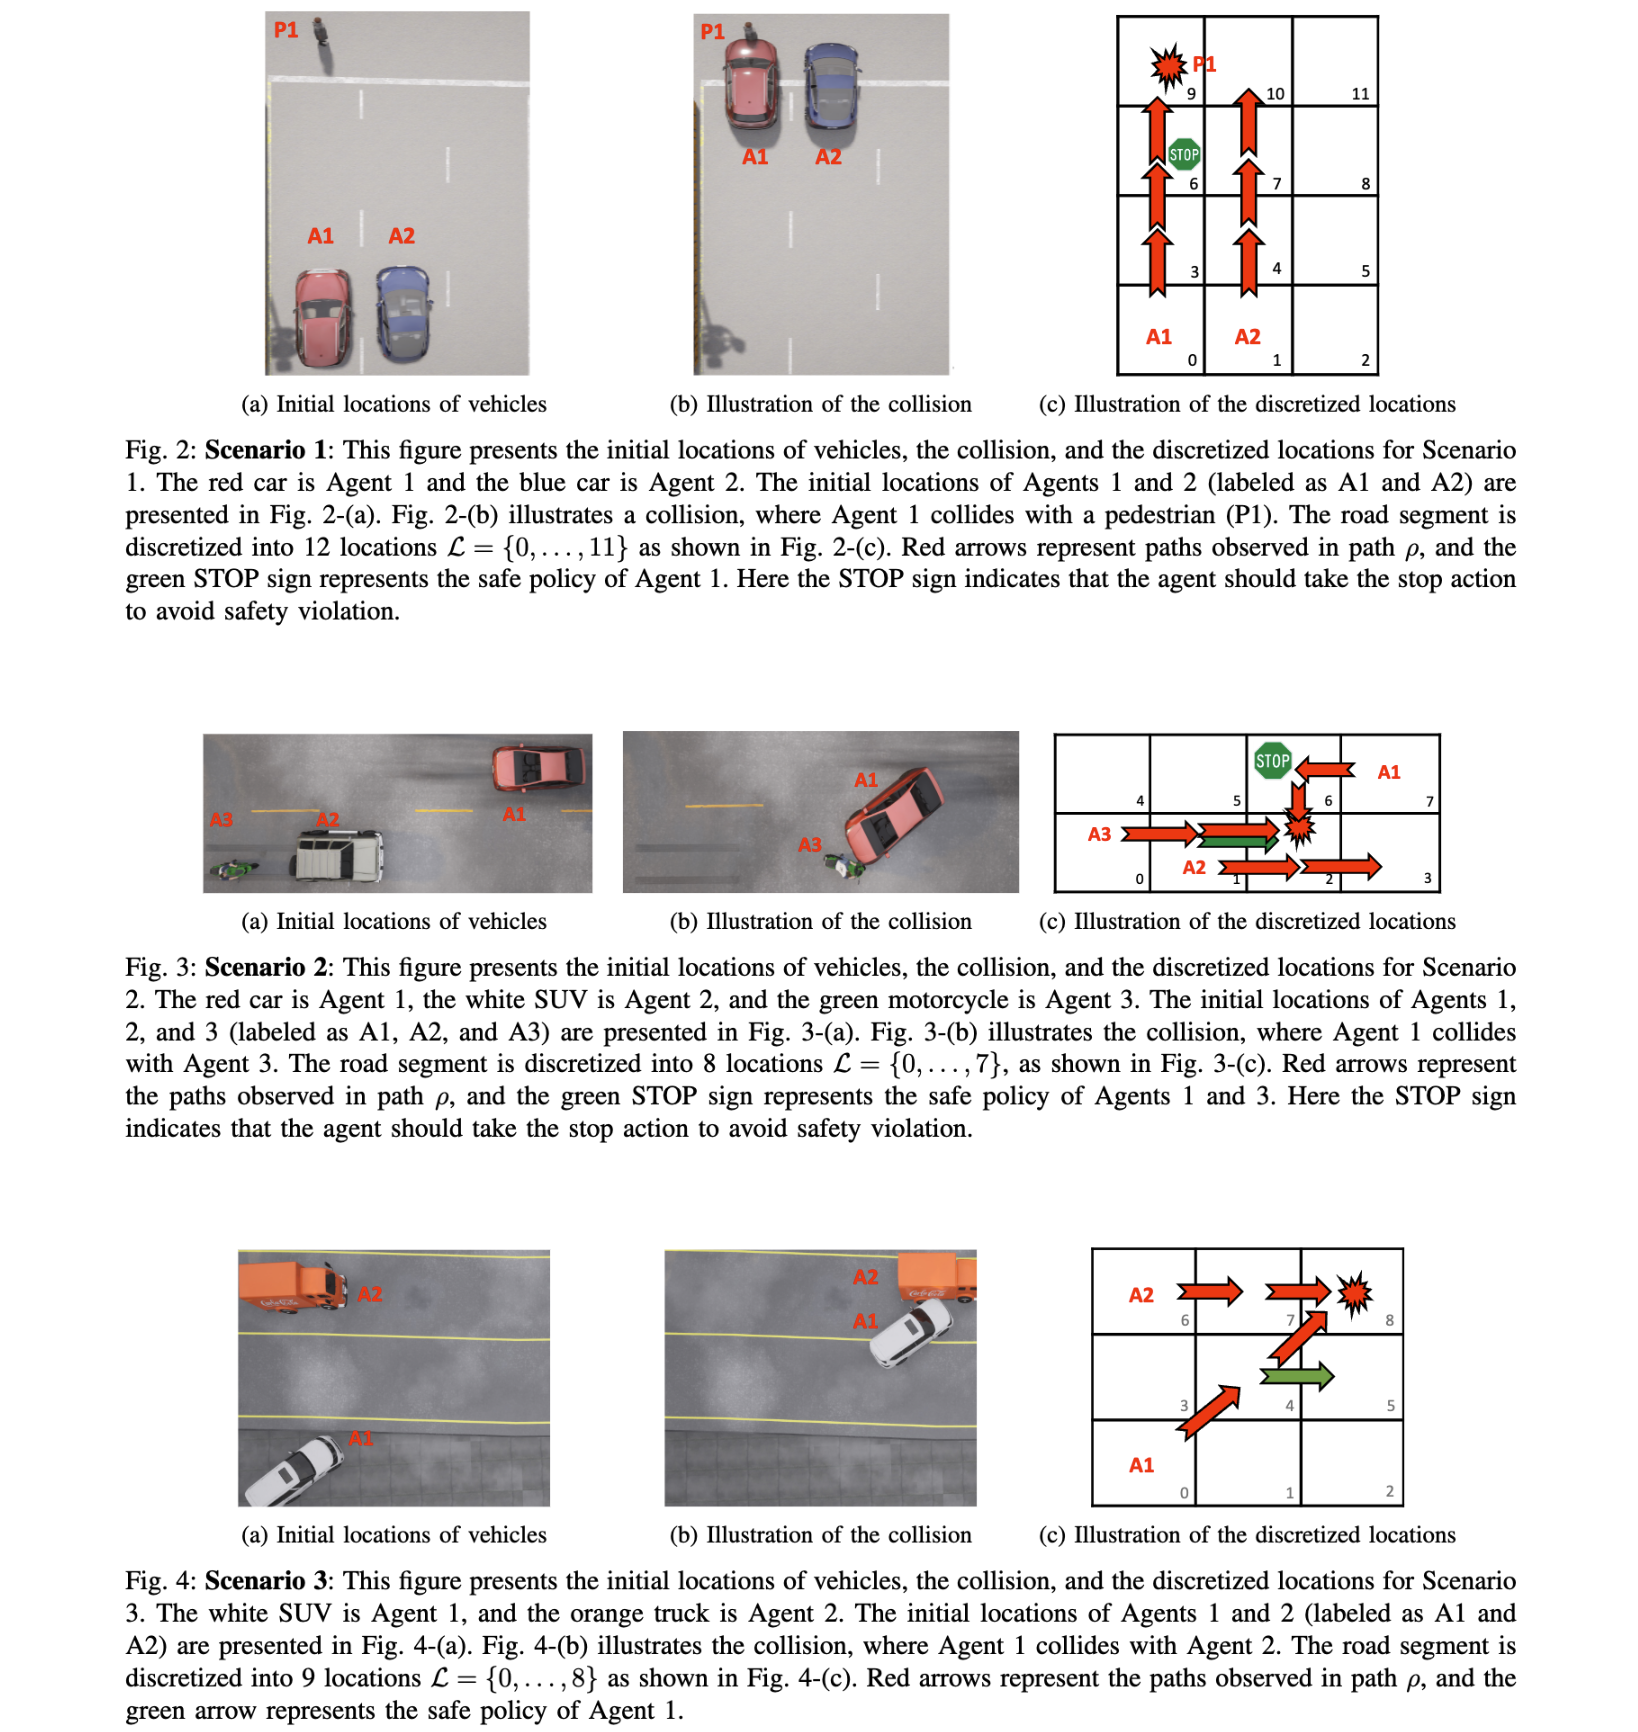
  2. Who is Responsible? Explaining Safety Violations in Multi-Agent Cyber-Physical Systems
    Who is Responsible? Explaining Safety Violations in Multi-Agent Cyber-Physical Systems
    Luyao Niu, Hongchao Zhang, Dinuka Sahabandu, and
    In 3rd IEEE International Conference on Assured Autonomy (ICAA), 2024
  3. Learning a Formally Verified Control Barrier Function in Stochastic Environment Learning a Formally Verified Control Barrier Function in Stochastic Environment
    Learning a Formally Verified Control Barrier Function in Stochastic Environment
    Manan Tayal, Hongchao Zhang, Pushpak Jagtap, and
    In 2024 IEEE 63rd Conference on Decision and Control (CDC), 2024
  4. Verification and Synthesis of Compatible Control Lyapunov and Control Barrier Functions
    Verification and Synthesis of Compatible Control Lyapunov and Control Barrier Functions
    Hongkai Dai, Chuanrui Jiang, Hongchao Zhang, and
    In 2024 IEEE 63rd Conference on Decision and Control (CDC), 2024
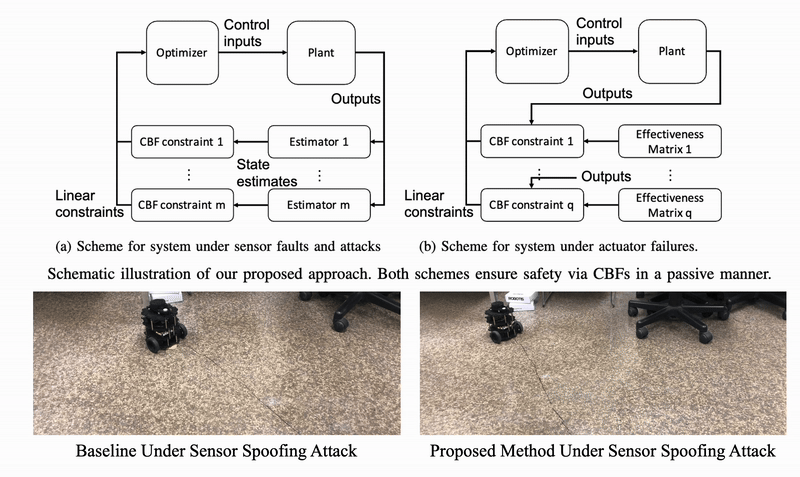
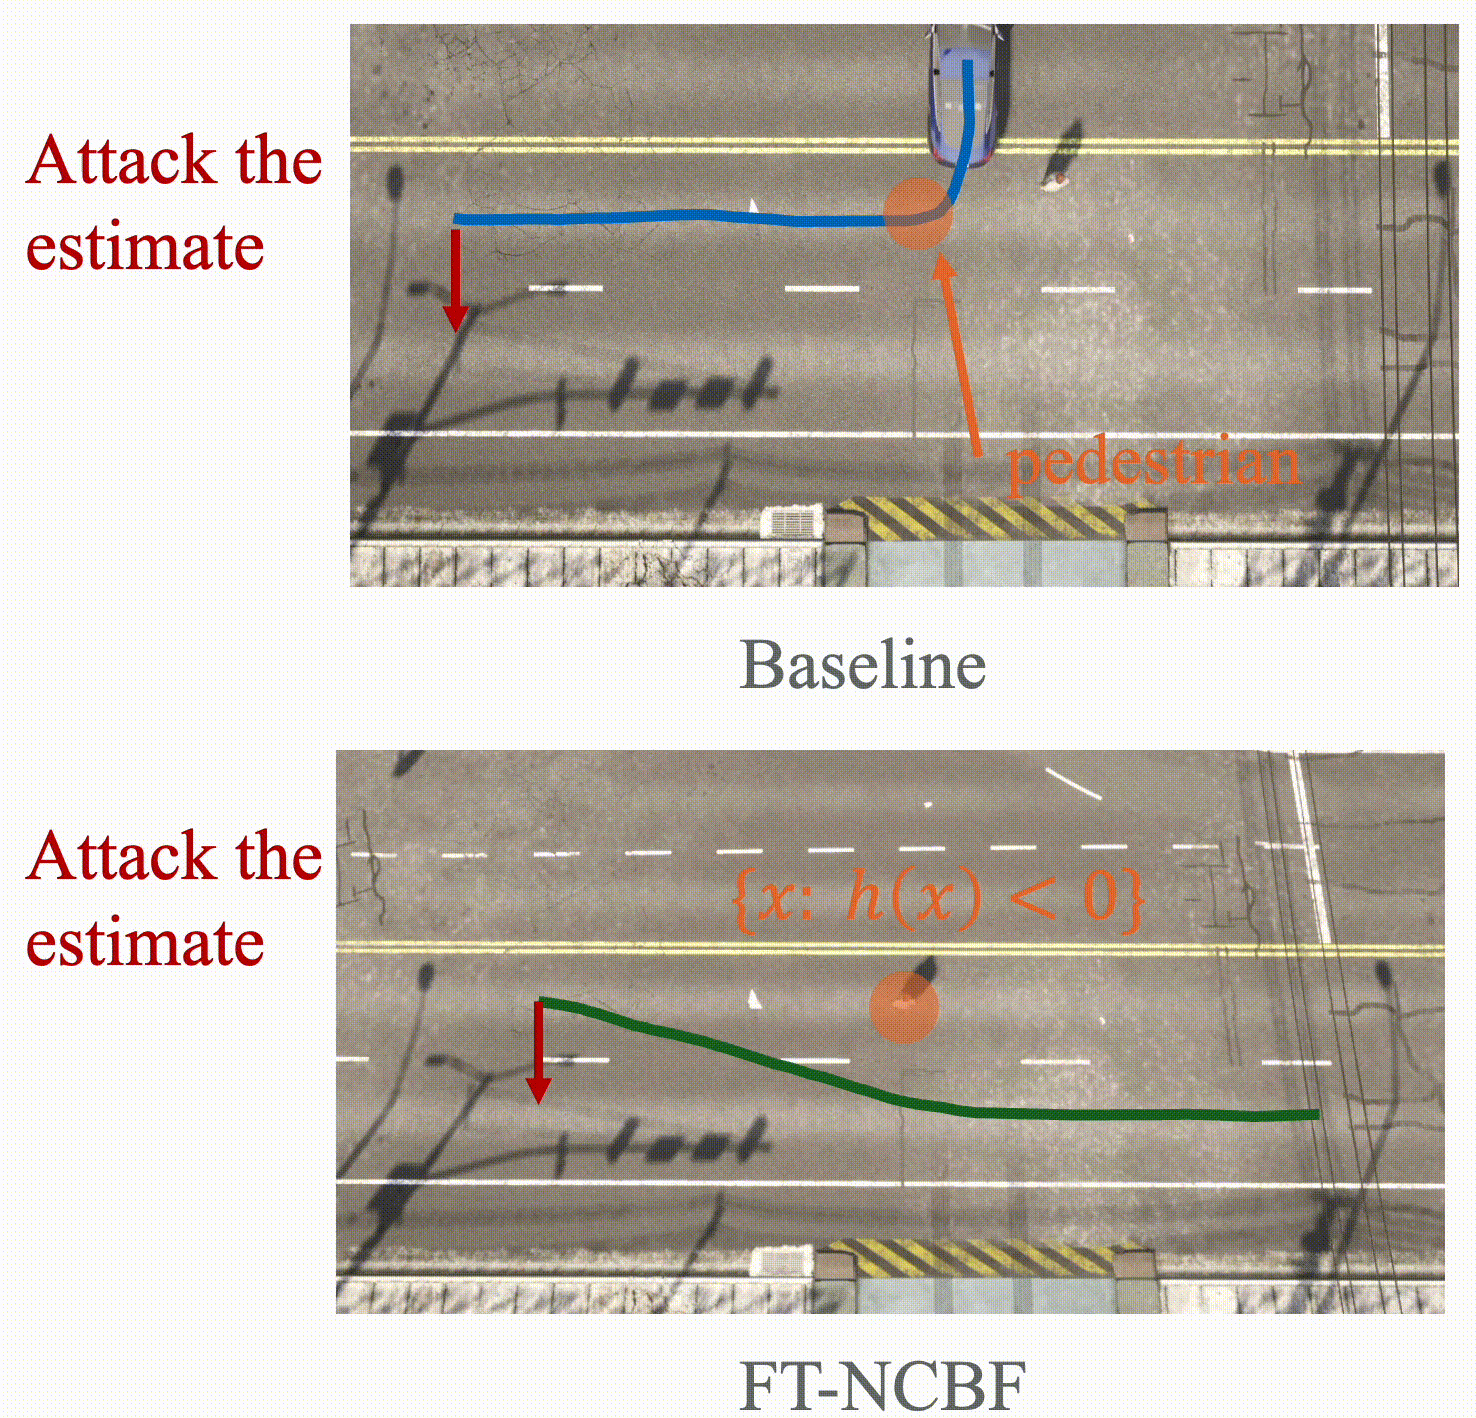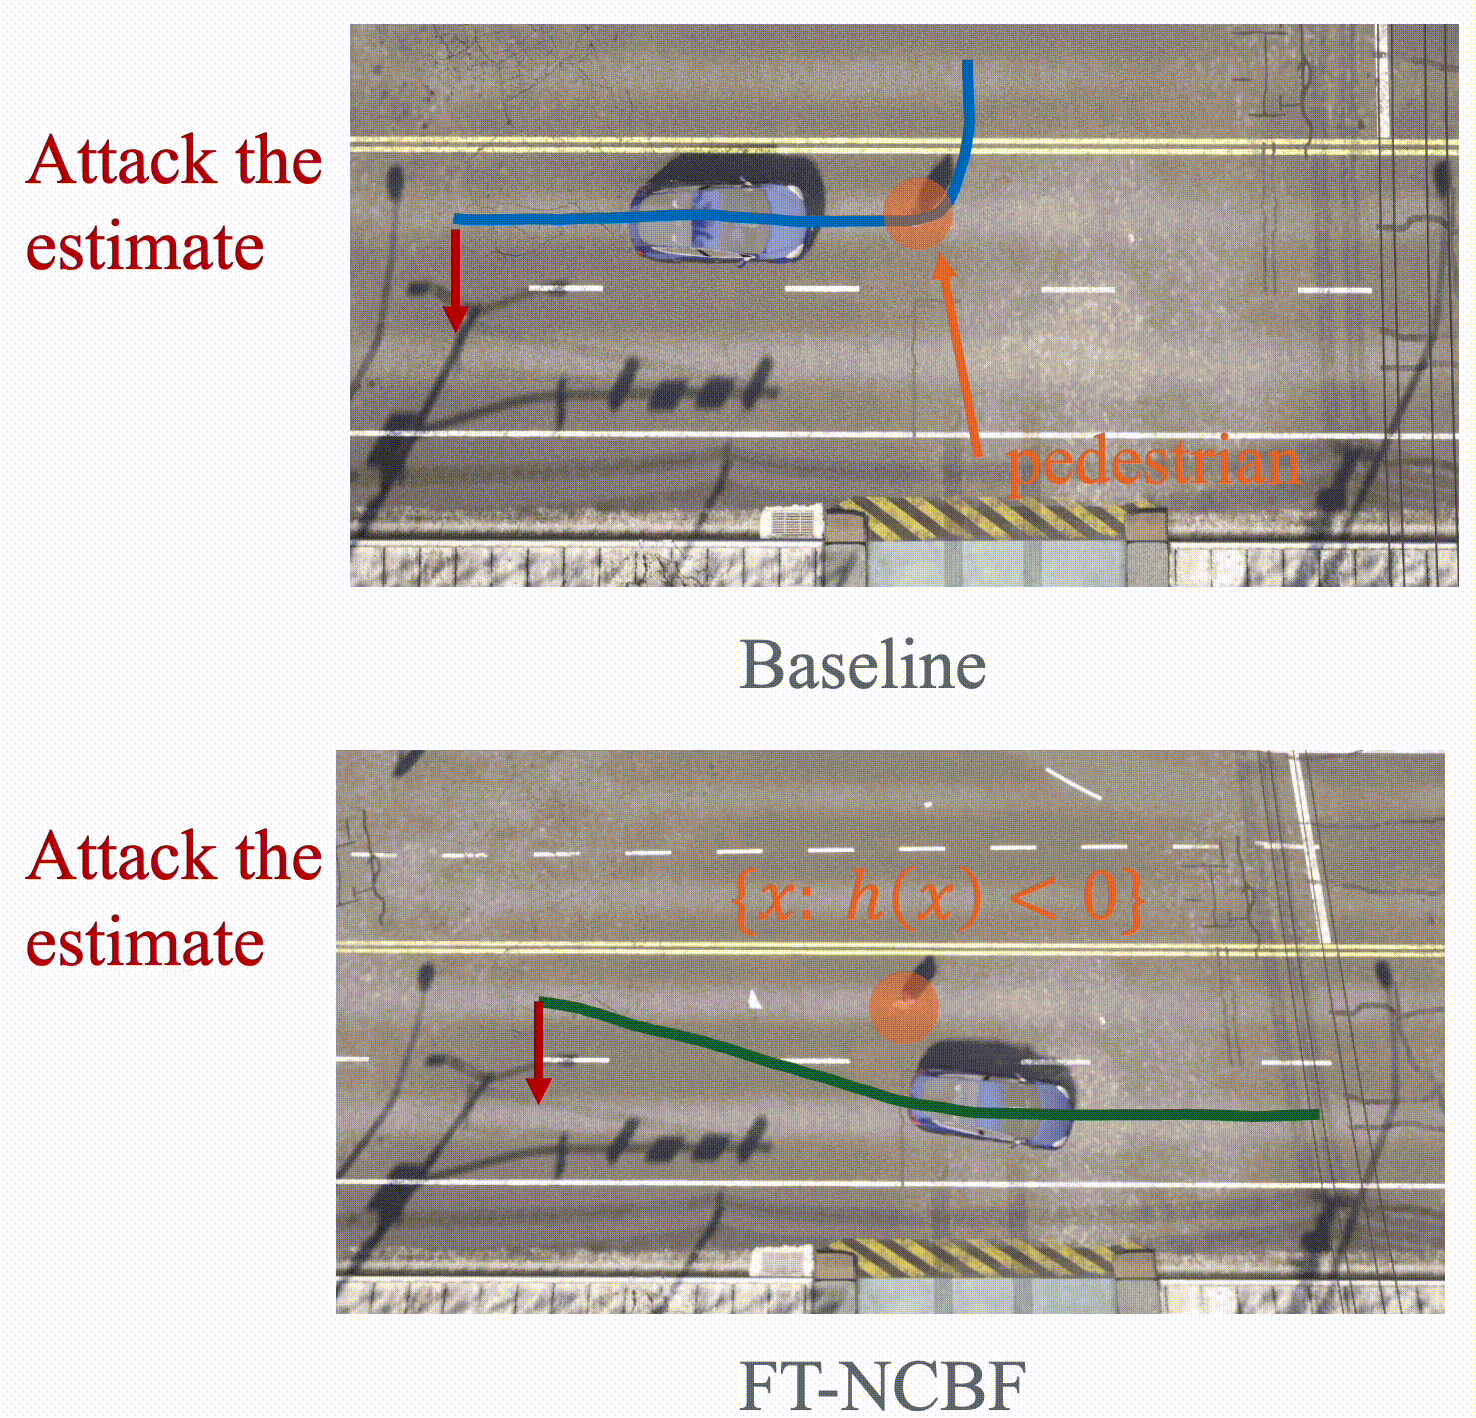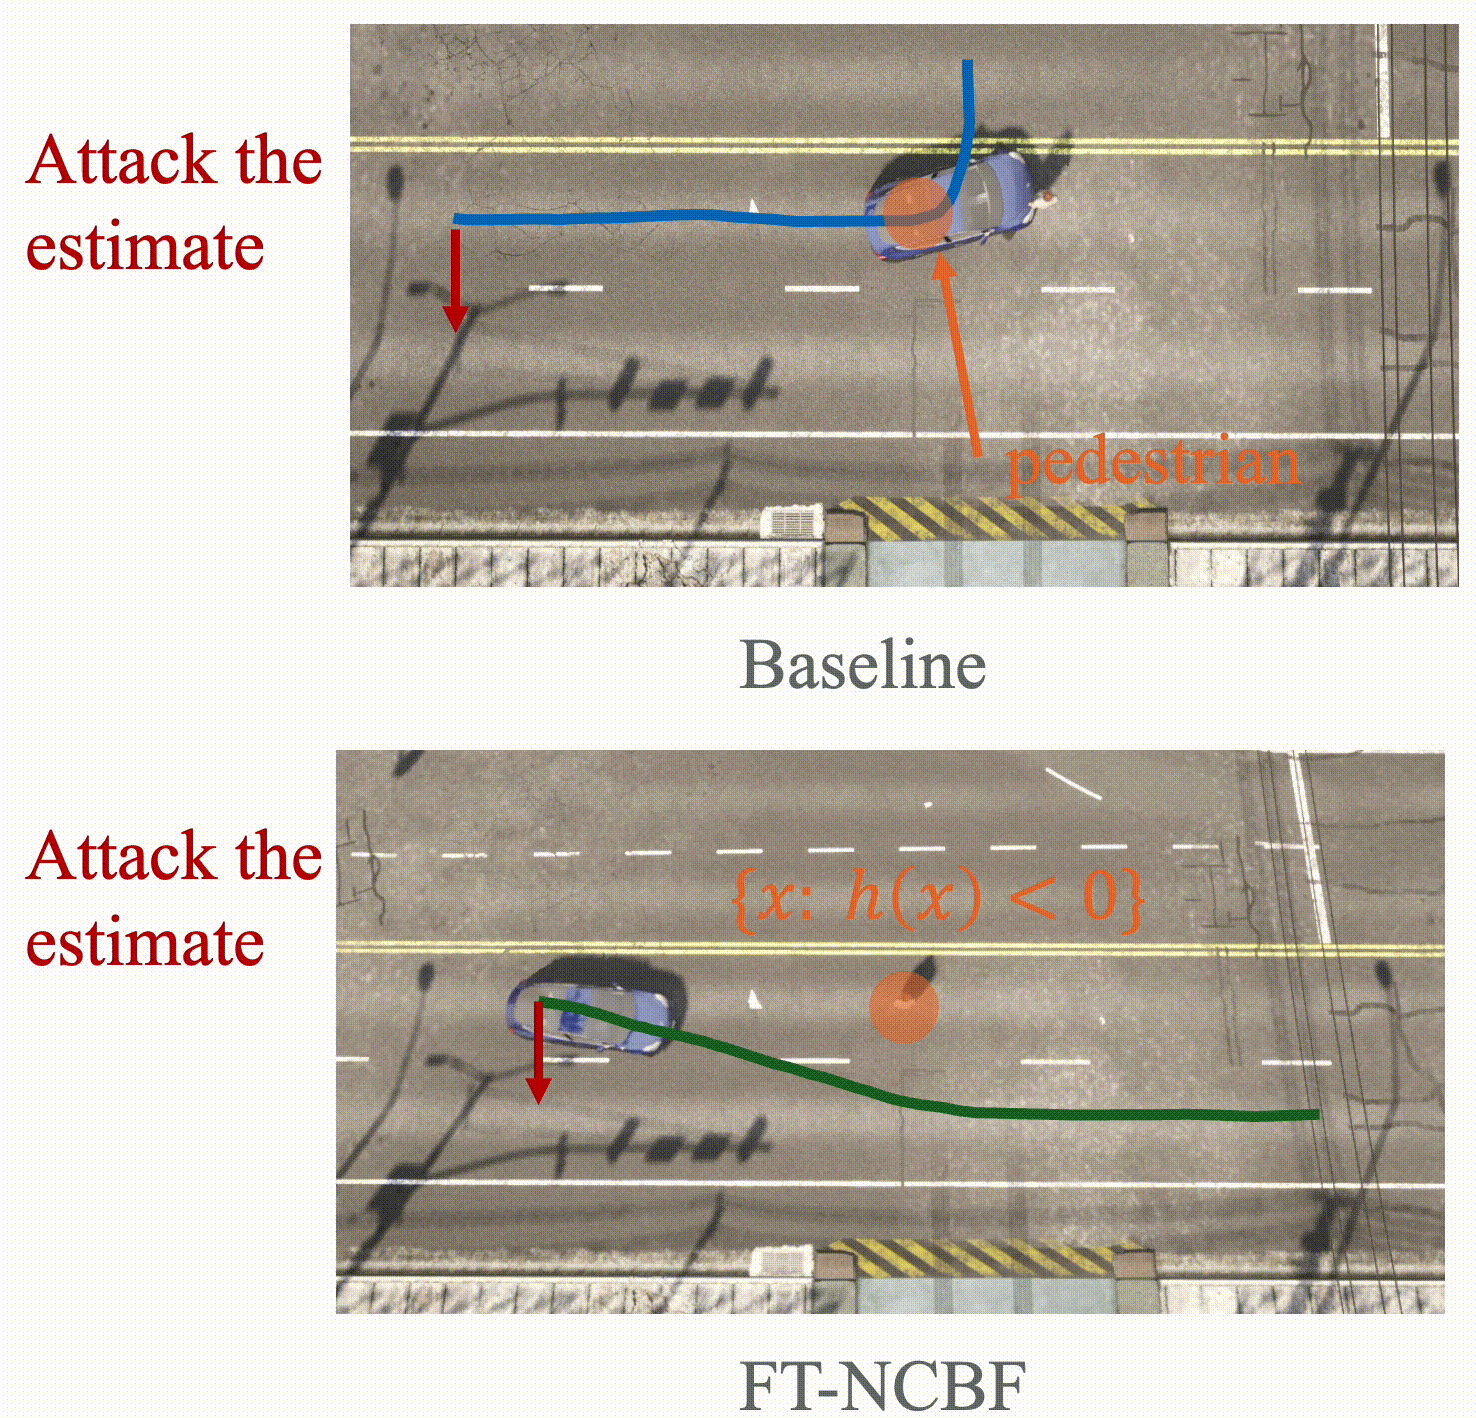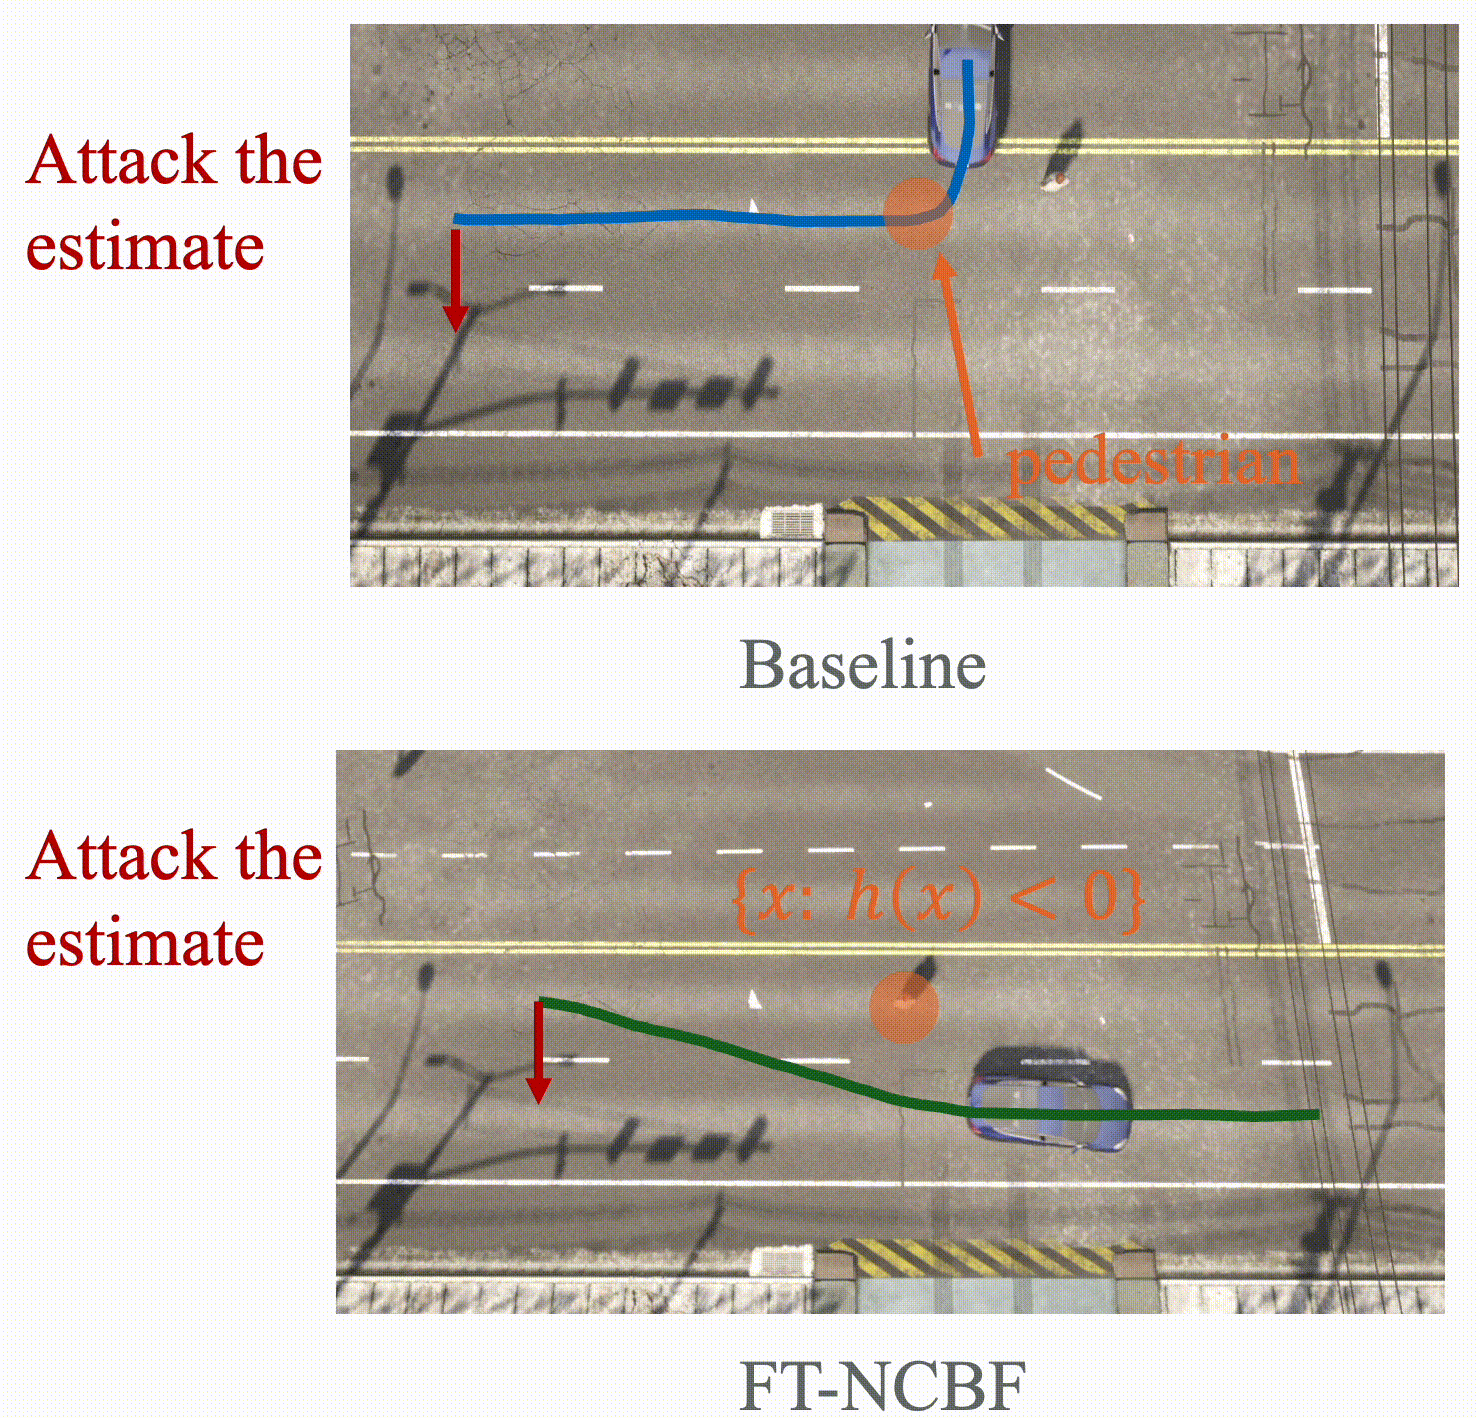
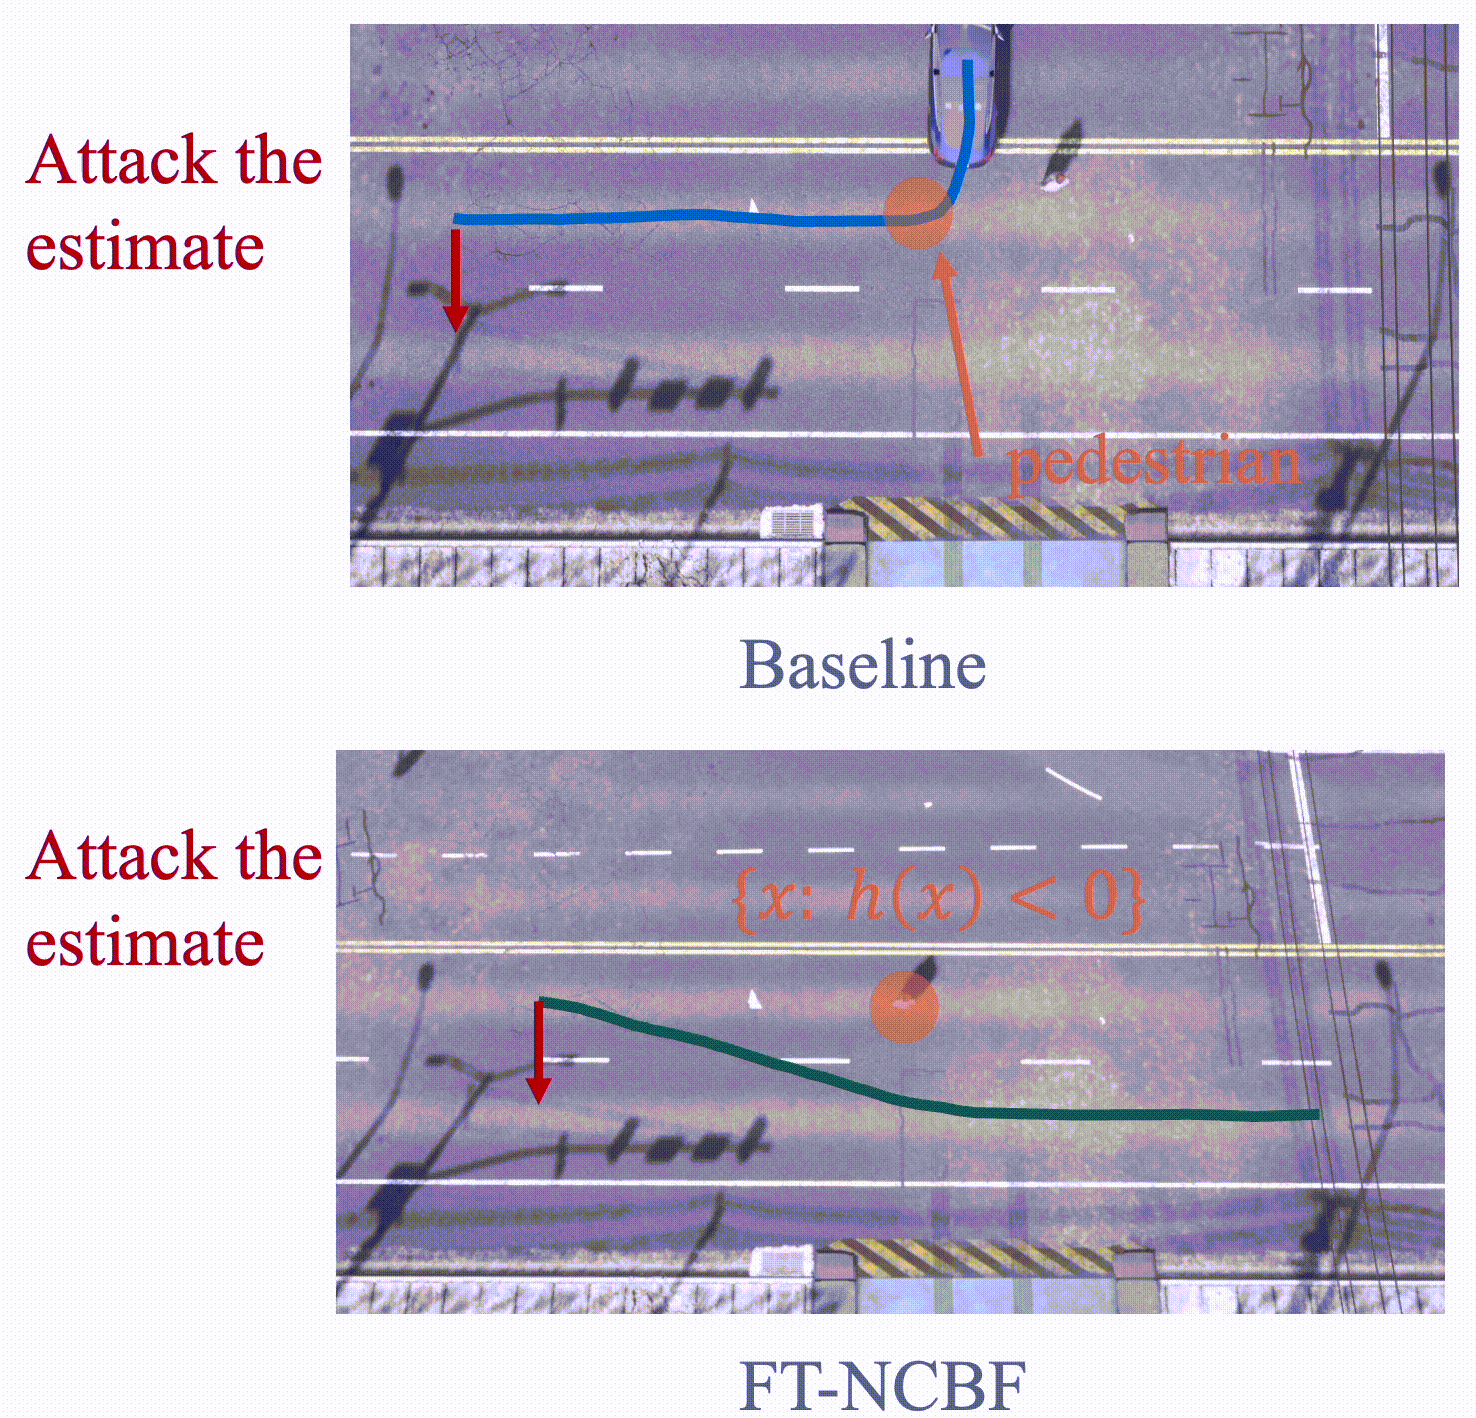
  5. Fault Tolerant Neural Control Barrier Functions for Robotic Systems under Sensor Faults and Attacks Fault Tolerant Neural Control Barrier Functions for Robotic Systems under Sensor Faults and Attacks
    Fault Tolerant Neural Control Barrier Functions for Robotic Systems under Sensor Faults and Attacks
    Hongchao Zhang, Luyao Niu, Andrew Clark, and
    In 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024

2023

  1. Cooperative Perception for Safe Control of Autonomous Vehicles under LiDAR Spoofing Attacks
    Cooperative Perception for Safe Control of Autonomous Vehicles under LiDAR Spoofing Attacks
    Hongchao Zhang, Zhouchi Li, Shiyu Cheng, and
    In Symposium on Vehicle Security and Privacy (VehicleSec), 2023
    General Motors AutoDriving Security Award
  2. Efficient Sum of Squares-Based Verification and Construction of Control Barrier Functions by Sampling on Algebraic Varieties
    Efficient Sum of Squares-Based Verification and Construction of Control Barrier Functions by Sampling on Algebraic Varieties
    Hongchao Zhang, Zhouchi Li, Hongkai Dai, and
    In 2023 62nd IEEE Conference on Decision and Control (CDC), 2023
  3. Exact Verification of ReLU Neural Control Barrier Functions
    Exact Verification of ReLU Neural Control Barrier Functions
    Hongchao Zhang, Junlin Wu, Yevgeniy Vorobeychik, and
    In Advances in Neural Information Processing Systems, 2023

2022

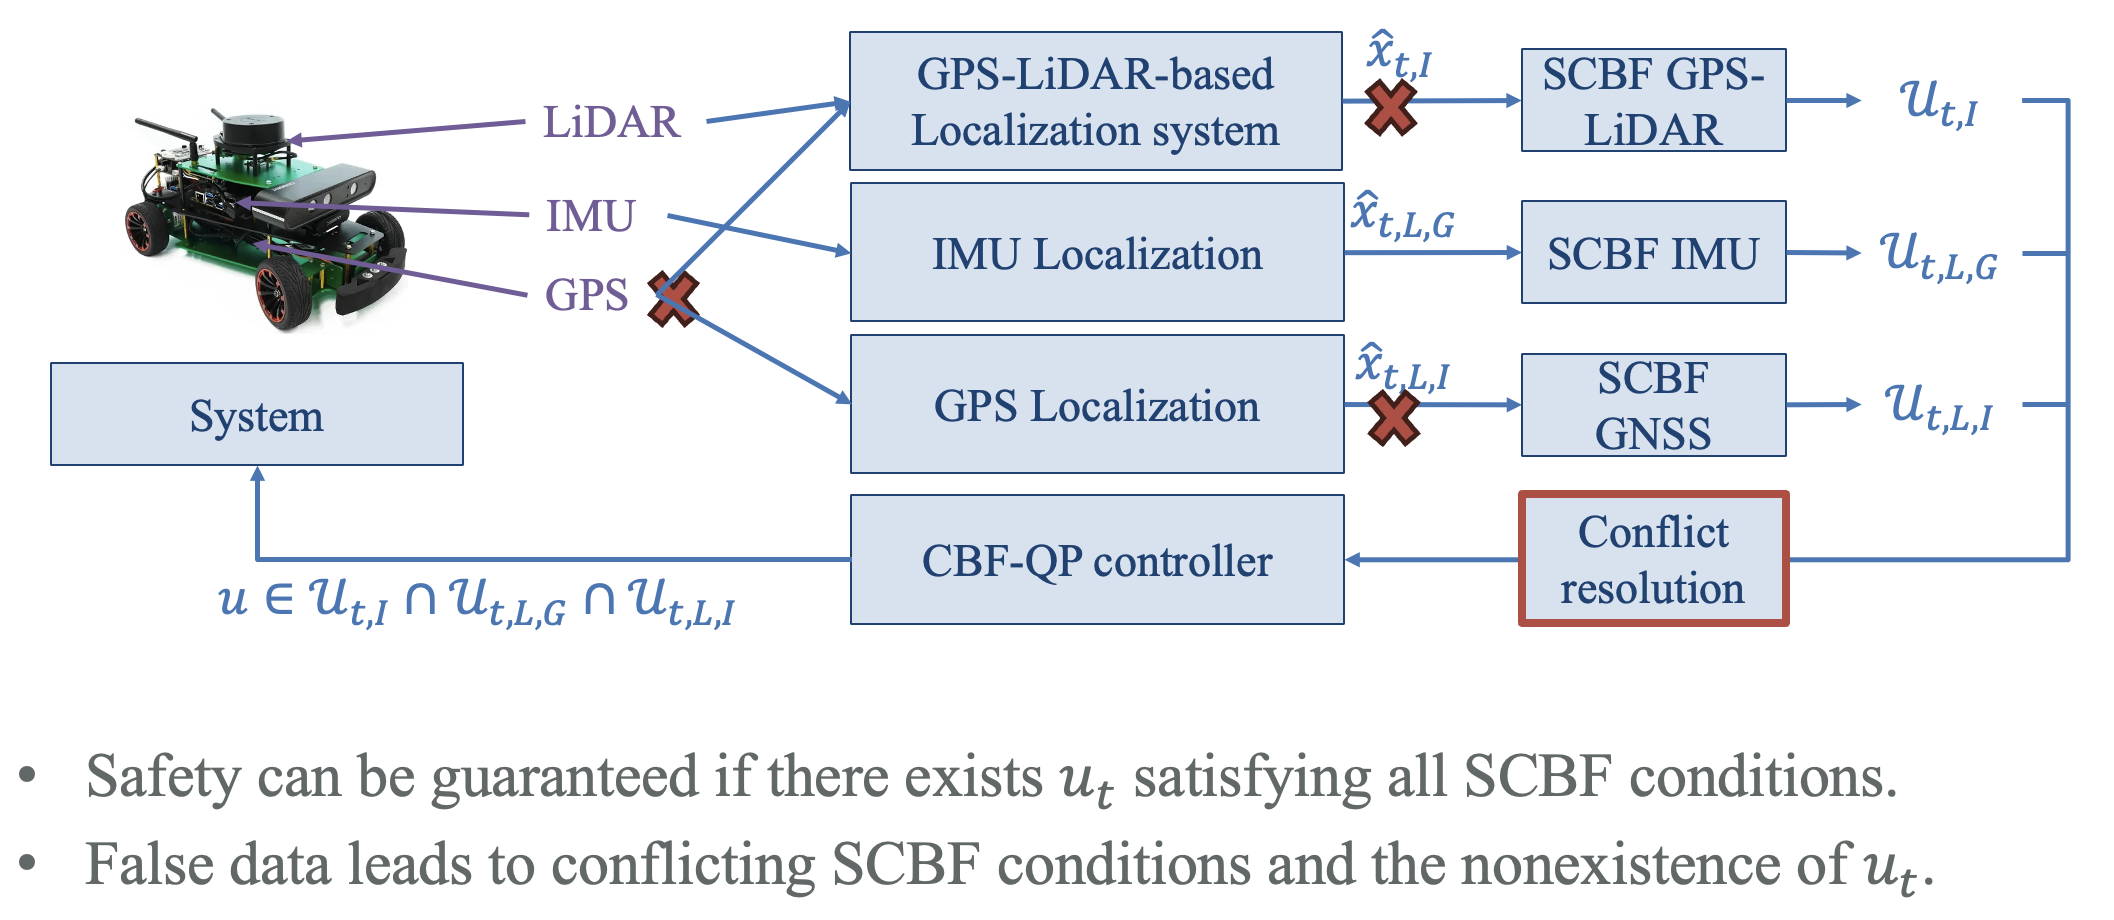
  1. Barrier Certificate based Safe Control for LiDAR-based Systems under Sensor Faults and Attacks
    Barrier Certificate based Safe Control for LiDAR-based Systems under Sensor Faults and Attacks
    Hongchao Zhang, Shiyu Cheng, Luyao Niu, and
    In 2022 IEEE 61st Conference on Decision and Control (CDC), 2022

2021

  1. Safety-Critical Control Synthesis for Unknown Sampled-Data Systems via Control Barrier Functions
    Safety-Critical Control Synthesis for Unknown Sampled-Data Systems via Control Barrier Functions
    Luyao Niu, Hongchao Zhang, and Andrew Clark
    In 2021 60th IEEE Conference on Decision and Control (CDC), 2021
  2. Model-based Reinforcement Learning with Provable Safety Guarantees via Control Barrier Functions Model-based Reinforcement Learning with Provable Safety Guarantees via Control Barrier Functions
    Model-based Reinforcement Learning with Provable Safety Guarantees via Control Barrier Functions
    Hongchao Zhang, Zhouchi Li, and Andrew Clark
    In 2021 IEEE International Conference on Robotics and Automation (ICRA), 2021

2020

  1. Control Barrier Functions for Safe CPS Under Sensor Faults and Attacks
    Control Barrier Functions for Safe CPS Under Sensor Faults and Attacks
    Andrew Clark, Zhouchi Li, and Hongchao Zhang
    In 2020 59th IEEE Conference on Decision and Control (CDC), 2020